VEX V5 Robotics

Project type
VEX Robotics
Role
Mechanical lead
Timeline
2021 – 2025
Tools & Technologies
VEX V5
Gearing
Mechanisms
Prototyping
Problem & Goal
Develop and refine mechanisms for object manipulation and autonomous collection.
Design & Build
As mechanical lead, I worked on structural design, assembly, gearing, and robot mechanisms.
Mechanical design: Worked on structural design, assembly, gearing, and object-manipulation mechanisms.
Robot builds: Developed mechanisms for a controller-operated cone-stacking robot and an autonomous robot that collected recycling bin contents and returned to its starting point.
Iteration: Used testing to refine the mechanisms and autonomous behavior.

Outcome
Cone-stacking and autonomous recycling-collection robots.
Testing and iteration refined the object-manipulation mechanisms and autonomous behavior across both robot builds.
What I learned
I learned how structural design, gearing, and mechanism choices affect a robot’s ability to manipulate objects. As mechanical lead, I developed my assembly and troubleshooting skills and learned to refine mechanisms through repeated testing.
Other works
Have a look at my other work

Custom RC Quadcopter
A custom aircraft developed from SolidWorks models through 3D printing, assembly, and flight testing.
Personal project
Mechanical design & prototyping
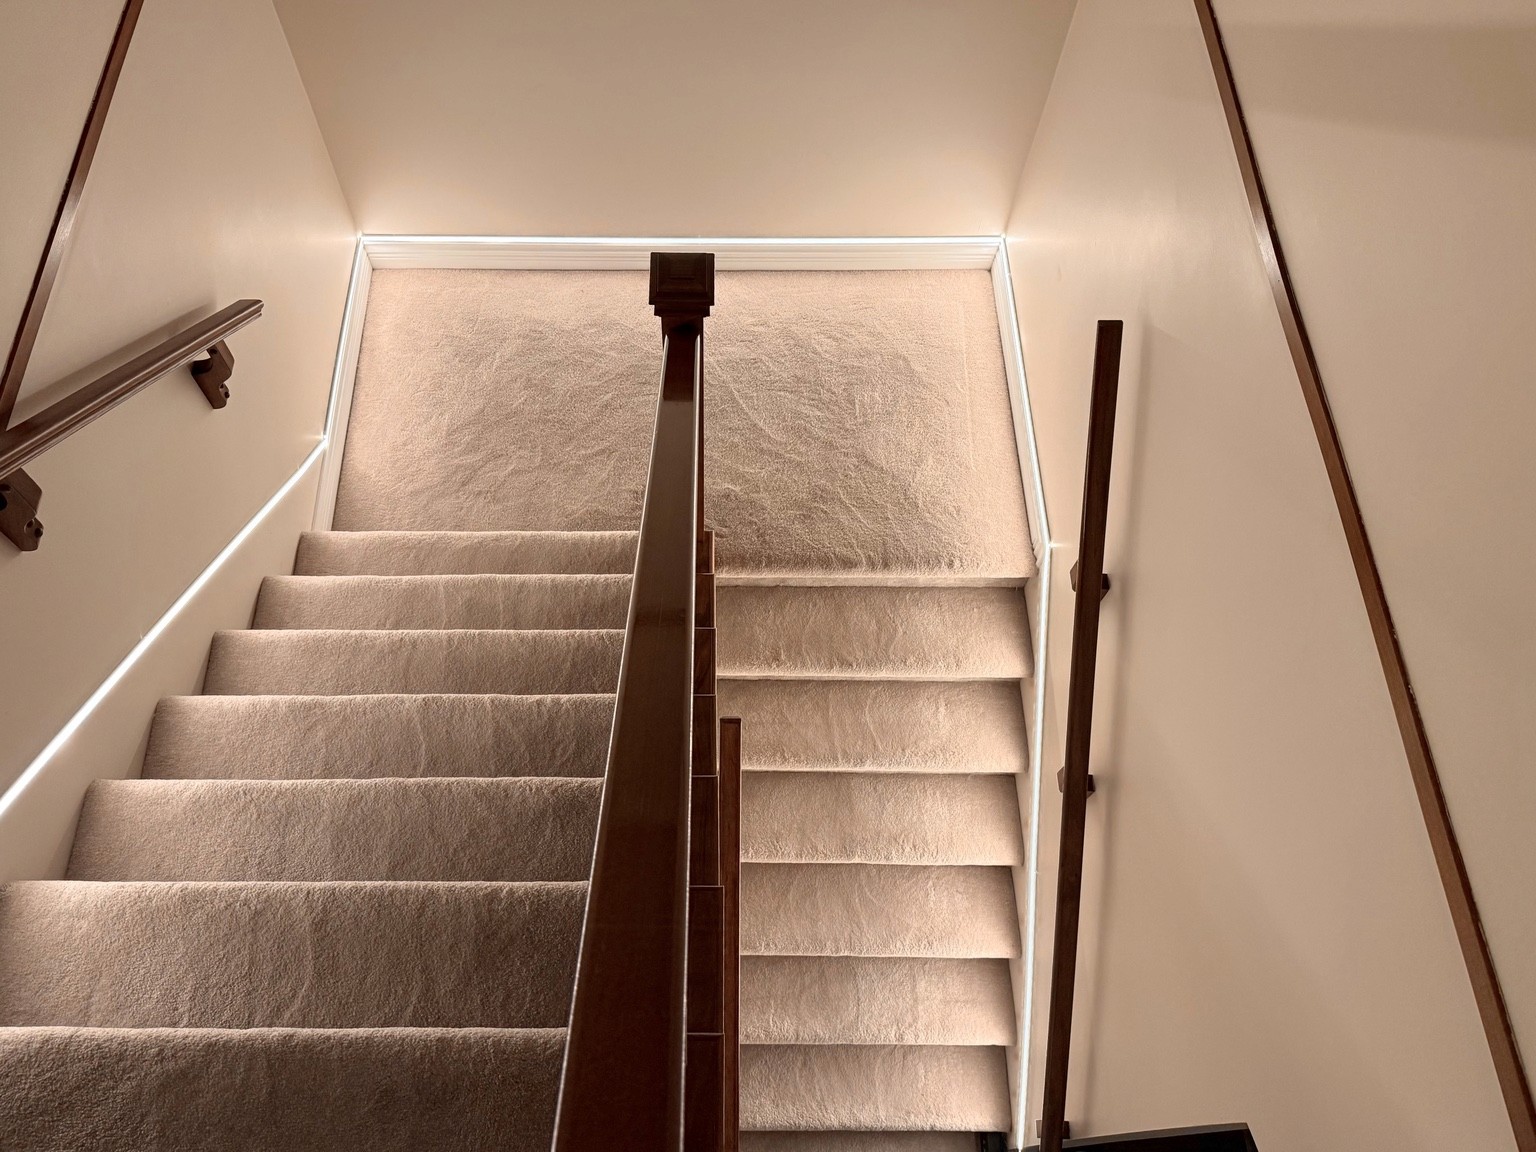
Motion-Activated Stair Lighting
A 24 V LED lighting system that responds to motion at either end of a staircase.
Personal project
Design & installation
Danial Hassan
Mechanical engineering · Vancouver, BC
© 2026 Danial Hassan