Autonomous Retrieval Claw
Project type
Personal project
Role
Mechanisms & controls
Timeline
Feb. 2026
Tools & Technologies
Arduino
Sensors
Servos
CAD
Problem & Goal
Combine object detection, control, and a gripping mechanism for autonomous pickup.
Design & Build
I developed the gripping mechanism and integrated the Arduino, sensor input, and servo actuation.
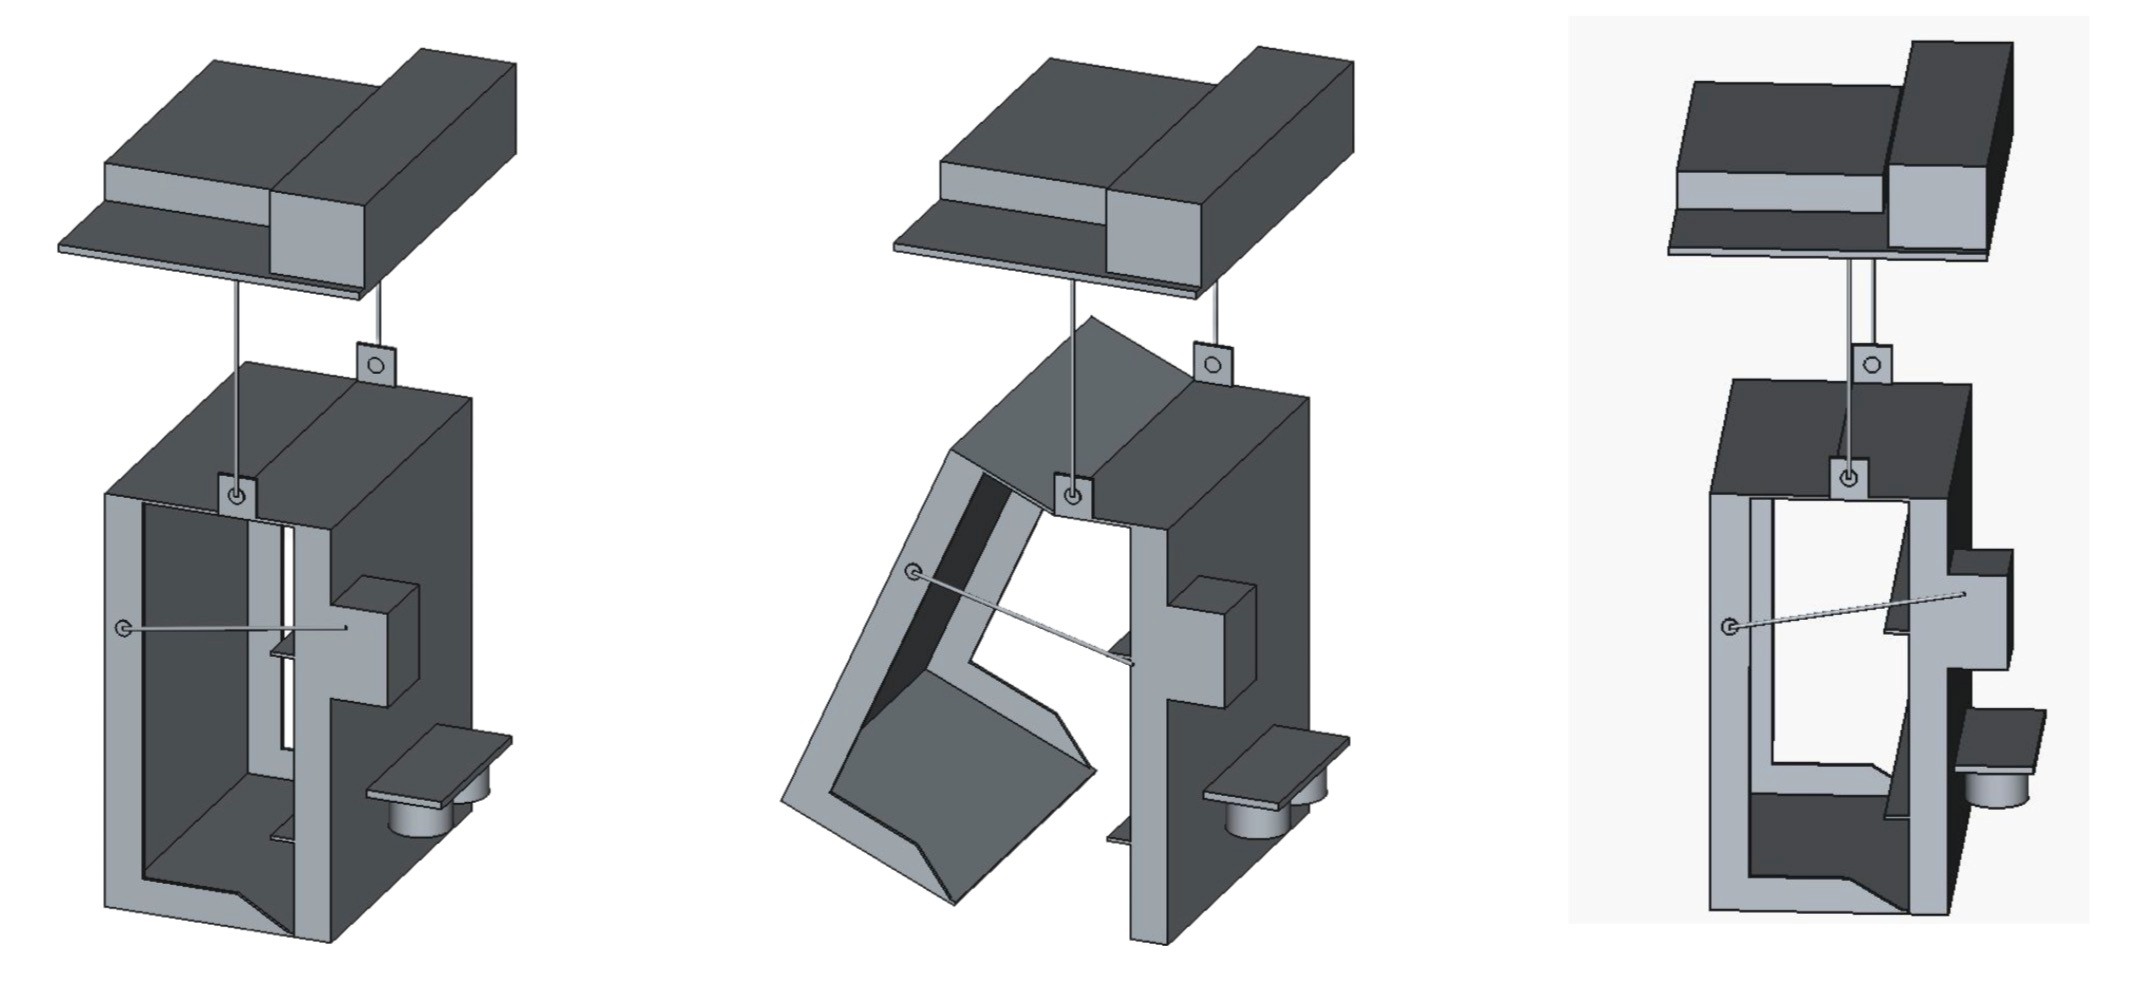
Mechanism design: Developed a claw that opens and closes to pick up objects on the ground; CAD views show its open and closed configurations.
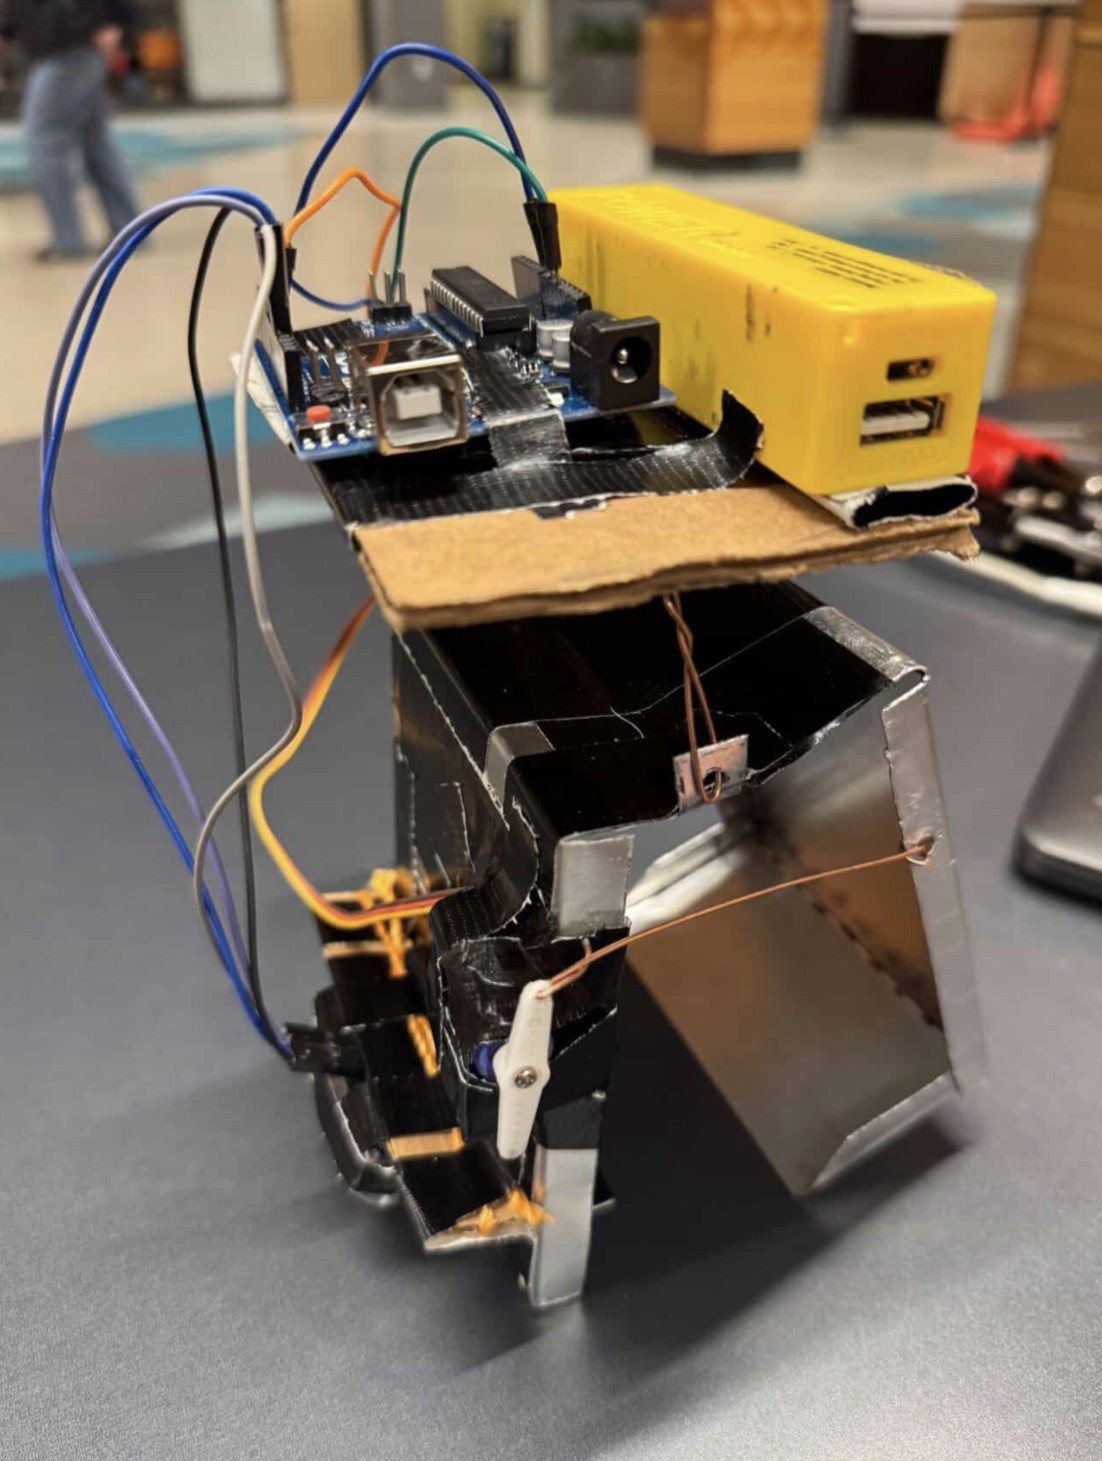
Controls & integration: Combined Arduino control, sensor input, and servo actuation with the mechanical gripping mechanism in a working prototype.
Outcome
A working prototype that detects and retrieves objects.
The assembled prototype integrated the gripping mechanism, sensor input, and servo control.
What I learned
I learned how to combine a mechanical gripping mechanism with Arduino control, sensor input, and servo actuation. Integrating them into a working prototype helped me understand the sequence from detecting an object to gripping and retrieving it.
Other works
Have a look at my other work

Custom RC Quadcopter
A custom aircraft developed from SolidWorks models through 3D printing, assembly, and flight testing.
Personal project
Mechanical design & prototyping
Motion-Activated Stair Lighting
A 24 V LED lighting system that responds to motion at either end of a staircase.
Personal project
Design & installation
Danial Hassan
Mechanical engineering · Vancouver, BC
© 2026 Danial Hassan